
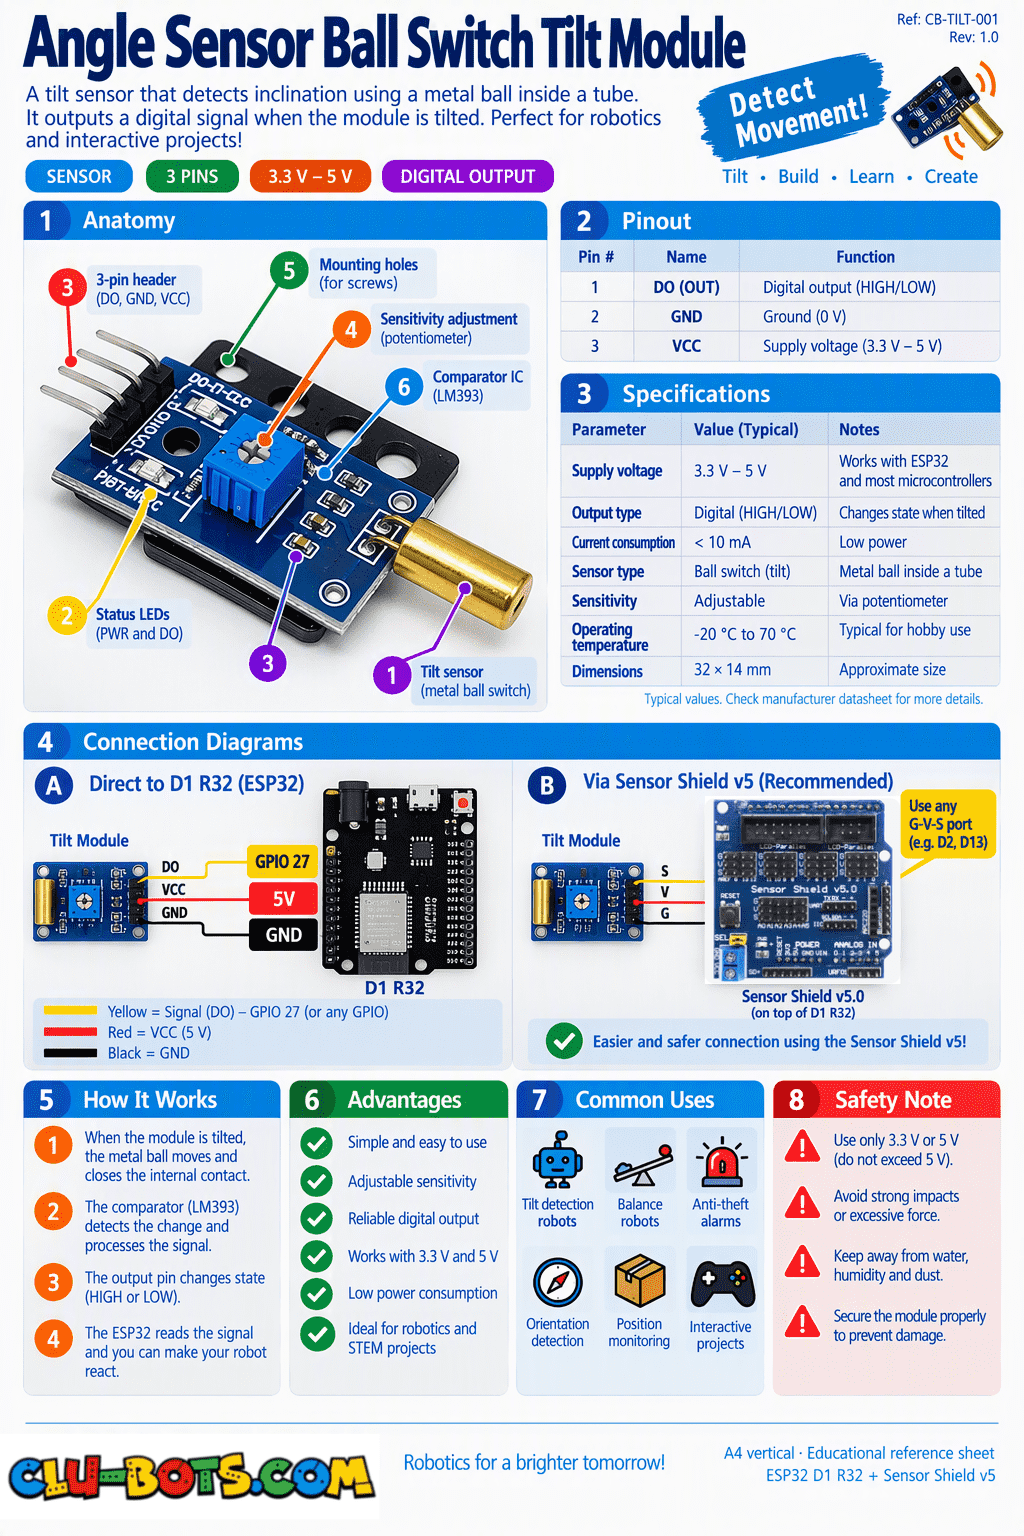
Angle Sensor Ball Switch Tilt
🎮 The Earthquake Detector

Module Goal: feel orientation. Inside this sensor a metal ball rolls when you tilt it your robot can know if it's standing straight or falling over. Every balancing robot starts here.
Goal:
discover what the rolling ball does to the signal.
Concepts:
Digital Input · Mechanical Sensing · Prediction
Before running: hold the sensor flat and still. Prediction: what number do you expect? Now predict: what happens when you tilt it sideways and the ball rolls? Test both guesses.
🔍 Detective rule: a metal ball rolling inside = a mechanical switch, so expect the inverted family.
import machine  # Library that controls the board's pins
import time  # Library for pauses

# Sets up pin26 as an input for the tilt sensor
# pin26 corresponds to D2 on the Sensor Shield V5.0
pin26 = machine.Pin(26, machine.Pin.IN)

while True:  # Repeat forever
    state = pin26.value()  # Read the raw tilt signal
    print("Tilt signal:", state)  # Send the raw value to the PC
    time.sleep_ms(300)  # Pause so the screen stays readable
Serial Monitor (tilt the board slowly, then set it flat again):
Tilt signal: 1
Tilt signal: 1
Tilt signal: 0 ← the ball rolled! (sensor tilted)
Tilt signal: 0
Tilt signal: 1 ← back flat, ball rolled home
💡 Note: inside that little module is a metal ball and two contacts. Flat: the ball rests at the bottom, connecting the circuit one way. Tilt: the ball rolls away, breaking the connection. You just read a moving piece of metal through a number. Shake it gently and watch the signal flicker that's the ball bouncing. Physics, live on your screen.
🎮 INTERPRET

Goal:
translate the signal into orientation words.
Concepts:
Conditional Translation · Meaning Making
import machine  # Library that controls the board's pins
import time  # Library for pauses

# Sets up pin26 as an input for the tilt sensor
# pin26 corresponds to D2 on the Sensor Shield V5.0
pin26 = machine.Pin(26, machine.Pin.IN)

while True:  # Repeat forever
    state = pin26.value()  # Read the raw tilt signal
    if state == 0:  # Inverted: 0 = ball rolled away
        print("TILTED I am falling over!")  # Alarm message
    else:  # 1 = ball resting = standing straight
        print("LEVEL standing proud")  # Calm message
    time.sleep_ms(300)  # Pause between readings
Serial Monitor:
LEVEL standing proud
LEVEL standing proud
TILTED I am falling over!
LEVEL standing proud
💡 Note: think ahead a robot vacuum uses this exact information to know when it's climbing a ramp or about to tip over. Same signal, same two numbers... but soon, in Level 2, TILTED will not print a message: it will stop the motors. The data never changes; what you DO with it grows with your skills.
🎮 Report Only Changes

Goal:
build a quiet reporter it speaks ONLY when the state changes, not every 300 ms.
Concepts:
Change Detection · Quiet Monitoring · Both Edges
import machine  # Library that controls the board's pins
import time  # Library for pauses

# Sets up pin26 as an input for the tilt sensor
# pin26 corresponds to D2 on the Sensor Shield V5.0
pin26 = machine.Pin(26, machine.Pin.IN)

prev = 1  # Remembers the previous reading (starts LEVEL)

while True:  # Repeat forever
    now = pin26.value()  # Fresh reading
    if now != prev:  # The state CHANGED (either direction!)
        if now == 0:  # It just became TILTED
            print(">>> Event: sensor TILTED")  # Report the fall
        else:  # It just became LEVEL again
            print(">>> Event: back to LEVEL")  # Report the recovery
    prev = now  # Save this reading for comparison
    time.sleep_ms(50)  # Fast checking so quick tilts are caught
Serial Monitor (tilt it, hold, set flat, tilt again):
>>> Event: sensor TILTED
(you hold it tilted silence)
>>> Event: back to LEVEL
>>> Event: sensor TILTED
💡 Note: new trick inside a familiar pattern the comparison now != prev catches BOTH edges: falling AND recovering. Previous programs only cared about one direction; this one narrates the whole story. A real earthquake station works the same way: it stays silent during calm and speaks at every change. A good monitor talks less, not more.
🎮 How Long Was the Tilt?

Goal:
measure the duration of each tilt episode from the moment it starts to the moment the ball comes home.
Concepts:
Event Timing · Waiting Loops · Duration Analysis
import machine  # Library that controls the board's pins
import time  # Library for pauses and time
# Sets up pin26 as an input for the tilt sensor
# pin26 corresponds to D2 on the Sensor Shield V5.0
pin26 = machine.Pin(26, machine.Pin.IN)
print("Tilt watch started tilt the sensor any time")  # Instructions
while True:  # Watch forever
    if pin26.value() == 0:  # A tilt just STARTED
        start = time.ticks_ms()  # Freeze the ms when the tilt began
        print("Tilt began...")  # Announce it
        while pin26.value() == 0:  # Wait WHILE it stays tilted...
            time.sleep_ms(10)  # ...checking every 10 ms
        duration = time.ticks_diff(time.ticks_ms(), start)  # End minus start
        print("The tilt lasted:", duration, "ms")  # Report the duration
        if duration < 500:  # Under half a second?
            print("That was a quick wobble")  # Short event
        else:  # Half a second or more
            print("That was a serious lean!")  # Long event
    time.sleep_ms(20)  # Calm checking between events
Serial Monitor:
Tilt watch started tilt the sensor any time
Tilt began...
The tilt lasted: 340 ms
That was a quick wobble
Tilt began...
The tilt lasted: 2100 ms
That was a serious lean!
💡 Note: compare this with the button's 5.4 the skeleton is the same, but notice the difference in flow: the button program ran in rounds ("press now!"), while this one watches quietly and reacts whenever an event happens. This second style event-driven is how real monitoring systems work: security cameras, smoke detectors, seismographs. They don't ask you to perform; they just wait and measure.
🎮 Balance Master

Goal:
the balance challenge keep the sensor perfectly LEVEL for 10 straight seconds. Every tilt counts as a failure. The PC delivers your verdict at the end.
Concepts:
Timed Challenge · Failure Counting · Verdict Logic
import machine  # Library that controls the board's pins
import time  # Library for pauses and time

# Sets up pin26 as an input for the tilt sensor
# pin26 corresponds to D2 on the Sensor Shield V5.0
pin26 = machine.Pin(26, machine.Pin.IN)

print("=== BALANCE MASTER ===")  # Mission title
print("Keep the sensor LEVEL for 10 seconds!")  # The rules
print("Ready...")  # Build suspense
time.sleep(1)  # One second
print("3...")  # Countdown
time.sleep(1)  # One second
print("2...")  # Countdown
time.sleep(1)  # One second
print("1...")  # Countdown
time.sleep(1)  # One second
print("START! Steady hands!")  # Go!
start = time.ticks_ms()  # Begin the 10-second clock
fails = 0  # Failure counter
while time.ticks_diff(time.ticks_ms(), start) < 10000:  # While under 10 seconds
    if pin26.value() == 0:  # Tilt detected FAILURE!
        fails += 1  # One more failure
        print("TILT! Failure number", fails)  # Report it
        while pin26.value() == 0:  # Wait until the sensor is level again
            time.sleep_ms(10)  # ...so ONE tilt episode = ONE failure
        print("Recovered... stay steady!")  # Encouragement
    time.sleep_ms(20)  # Fast checking
print("TIME UP!")  # End of challenge
if fails == 0:  # Zero failures?
    print("PERFECT BALANCE! You are a true master!")  # Best verdict
elif fails <= 2:  # One or two failures?
    print("Nice! Only", fails, "failures almost perfect")  # Good verdict
else:  # Three or more
    print("Wobbly hands!", fails, "failures train again!")  # Try again
Serial Monitor:
=== BALANCE MASTER ===
Keep the sensor LEVEL for 10 seconds!
Ready...
3...
2...
1...
START! Steady hands!
TILT! Failure number 1
Recovered... stay steady!
TILT! Failure number 2
Recovered... stay steady!
TIME UP! Nice! Only 2 failures almost perfect
💡 Note: this mission reuses your entire toolkit without teaching anything new countdown (from the bumper storm), timed loop, waiting cleanup, and now a graded verdict: three possible endings instead of one. Notice how if / elif / else turned a number into a judgment. Challenge a classmate: who achieves PERPECT BALANCE first? Then ask yourselves a Segway, a rocket, a walking robot: they all do exactly this, hundreds of times per second, just with a much faster sensor and motors instead of verdicts.